Jie Fan

I am currently a Computer Vision Consultant & Subproject Leader at ROBO Medical Technology Co., Ltd., where I develop vision and AI systems for digestive endoscopic surgical robotics. I received my Ph.D. in BioRobotics from Scuola Superiore Sant'Anna (SSSA) and the Italian Institute of Technology (IIT), advised by Prof. Barbara Mazzolai and Prof. Paolo Dario.

Before my Ph.D., I completed an M.Sc. in Control System and Automation Engineering at INSA de Lyon and a B.S. in Computer Science at Northwestern Polytechnical University, supervised by Prof. Tao Yang.

Jie Fan profile photo

Research

I am interested in the intersecting fields of computer vision, robotics, geometric representation learning, and multimodal AI. I develop perception and learning methods for 3D reconstruction, uncertainty-aware sensing, and robotic autonomy, with applications in surgical robotics, biomedical imaging, bioinspired soft robotics, and intelligent inspection.

Experience

Computer Vision Consultant & Subproject Leader

ROBO Medical Technology Co., Ltd. | Hangzhou, China | Mar. 2023 - Present

I develop computer vision and AI systems for digestive endoscopic surgical robotics, including multi-modal CT and endoscopic data processing, 3D reconstruction, lesion detection, localization, segmentation, keypoint tracking, and real-time visual pose estimation for tendon-driven articulated surgical tools.

Publications

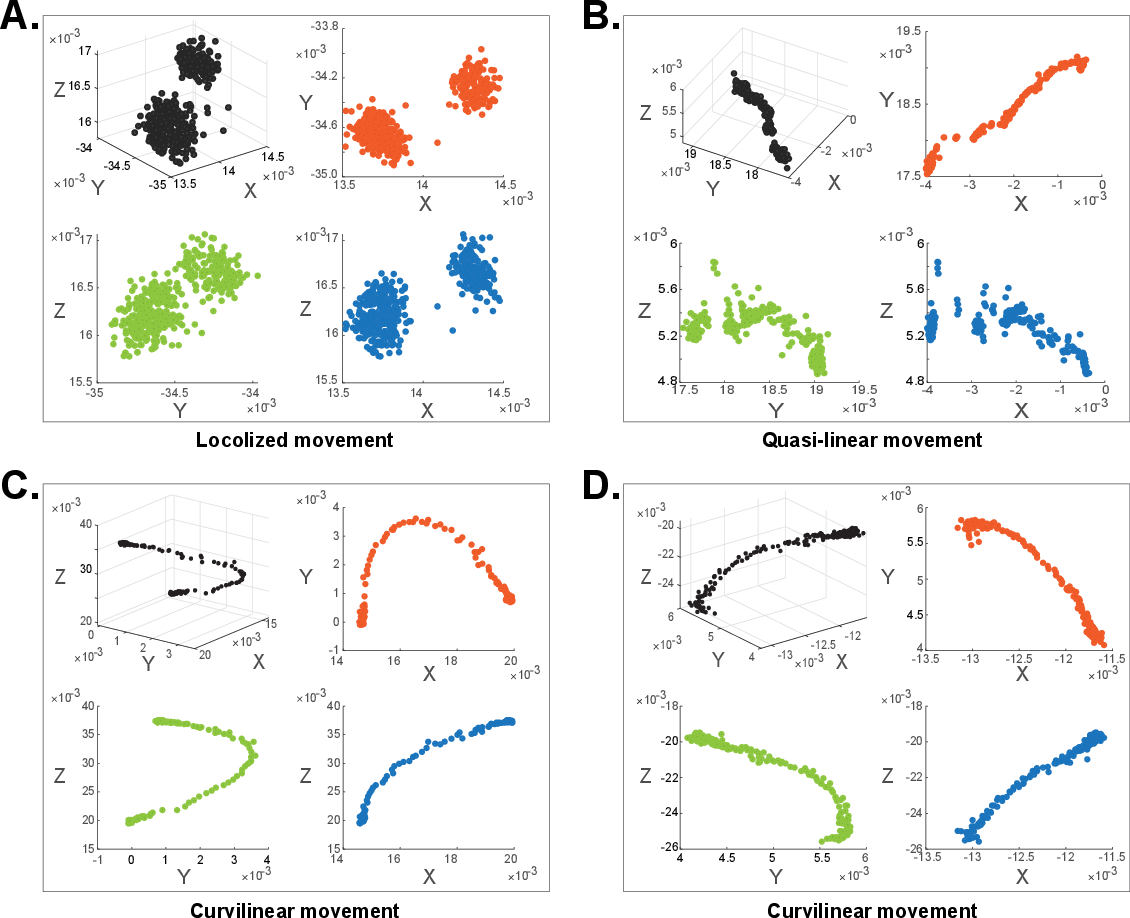
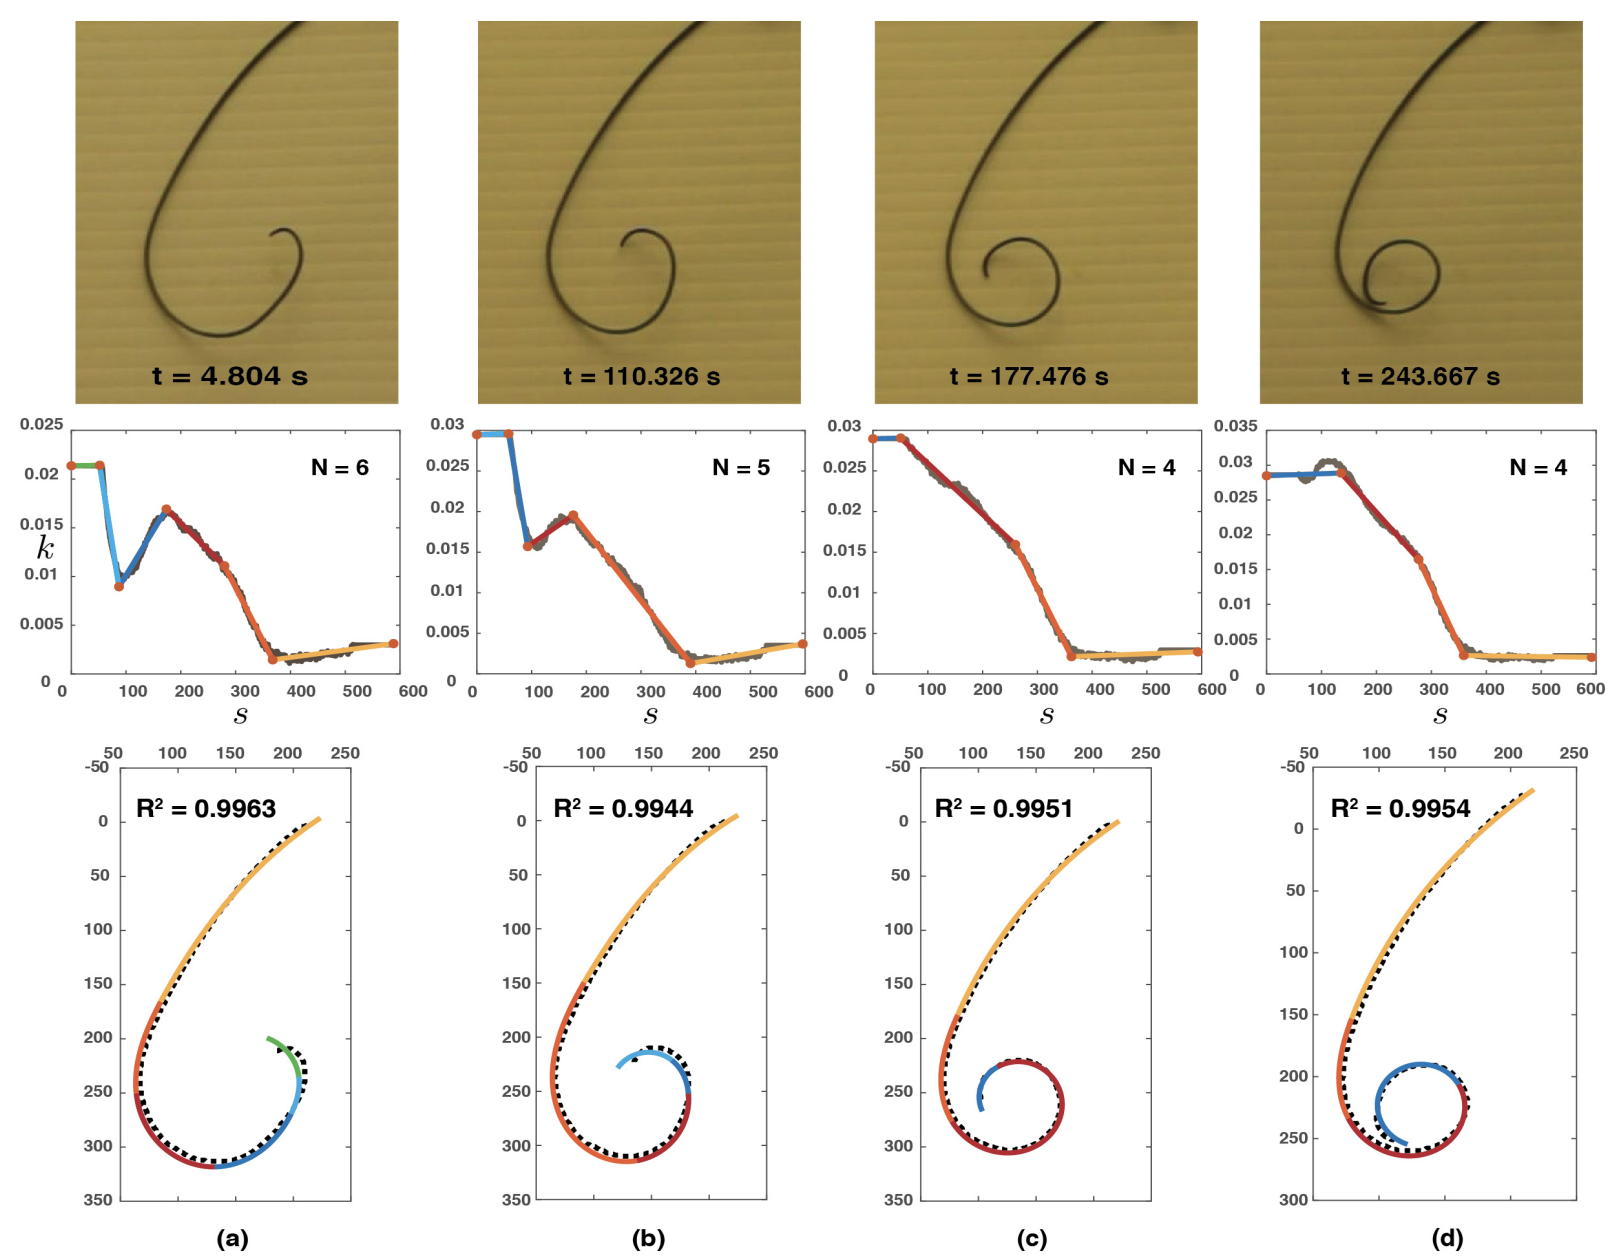
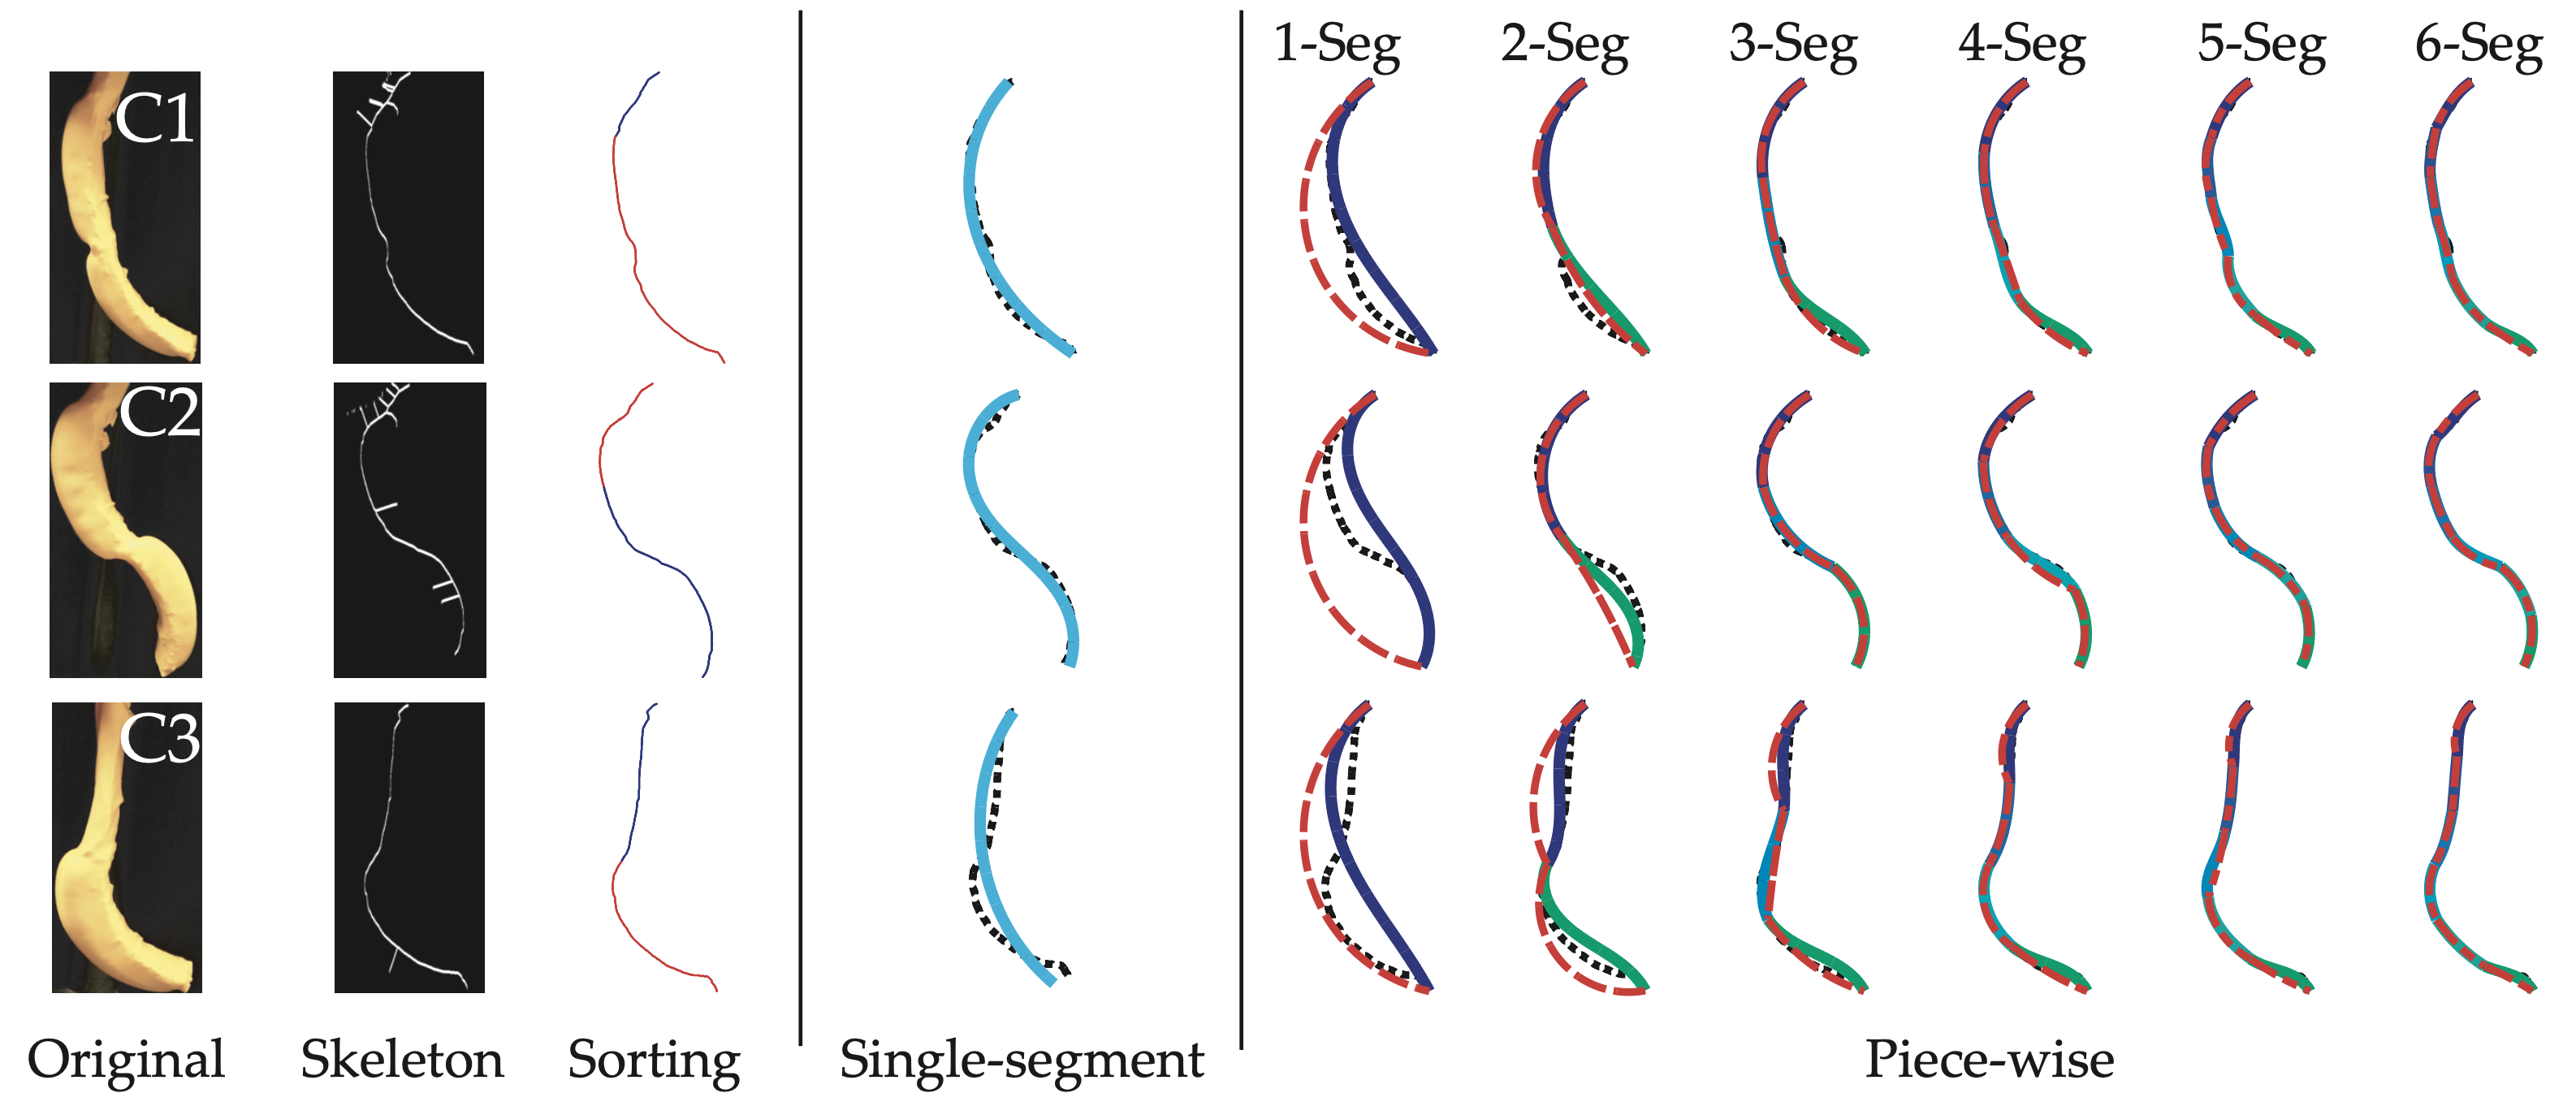
Image-based Morphological Characterization of Filamentous Biological Structures with Non-constant Curvature Shape Feature

Jie Fan, Francesco Visentin, Barbara Mazzolai, Emanuela Del Dottore

International Journal of Computer Vision, 2026.

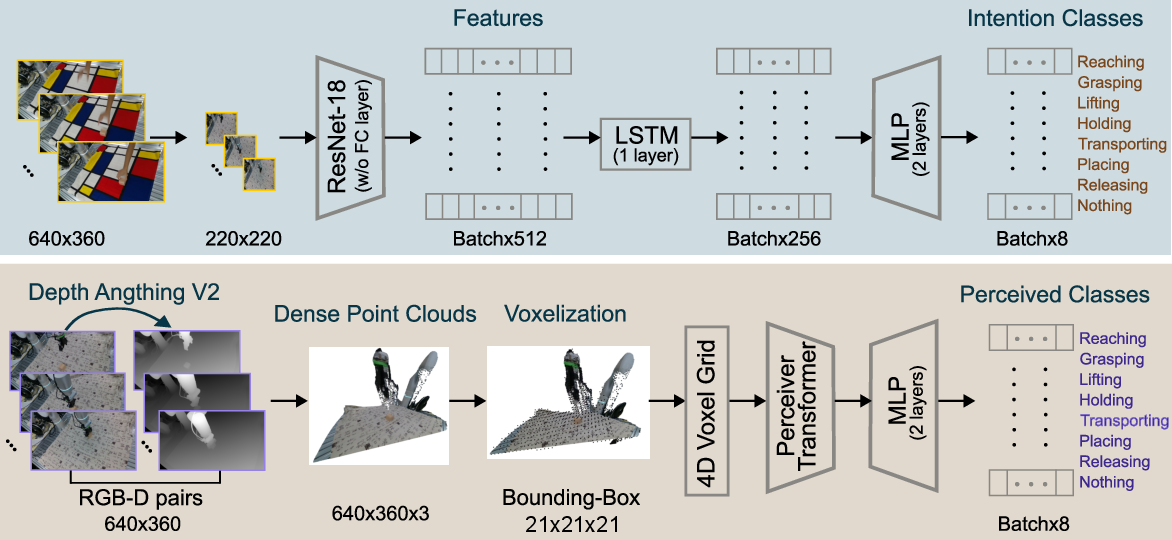
Toward Aligning Human and Robot Actions via Multi-Modal Demonstration Learning

Azizul Zahid, Jie Fan, Farong Wang, Ashton Dy, Sai Swaminathan, Fei Liu

ICRA Workshop on Human-Centered Robot Learning in the Era of Big Data and Large Models, 2025.

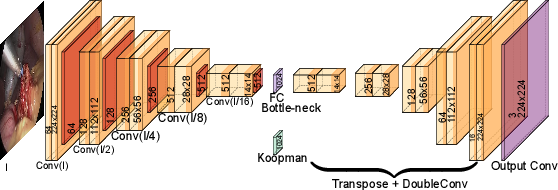
Learning Latent Linear Dynamics from Surgical Videos via Koopman-based Visual Representations

Luke Whatley, Andrei Cozma, Jie Fan, Hairong Qi, Fei Liu

ICRA Workshop on Robot-Assisted Medical Imaging, 2025.

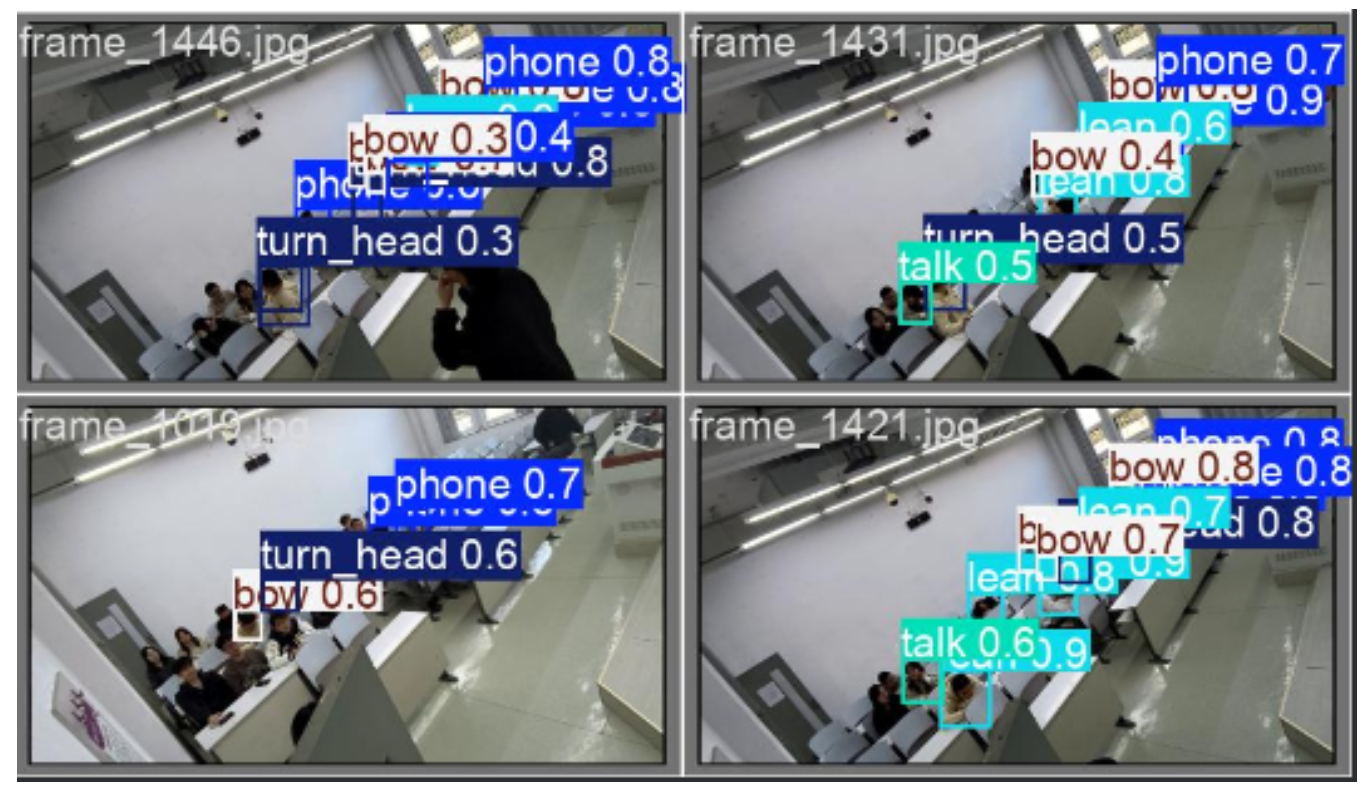
Intelligent Detection of Student Classroom Behavior Based on an Improved YOLOv8 Model

Meng Zhou, Huifang Zhang, Yuchao Peng, Jing Wang, Zhe Dong, Jie Fan

International Workshop on Advanced Computational Intelligence and Intelligent Informatics, 2025.

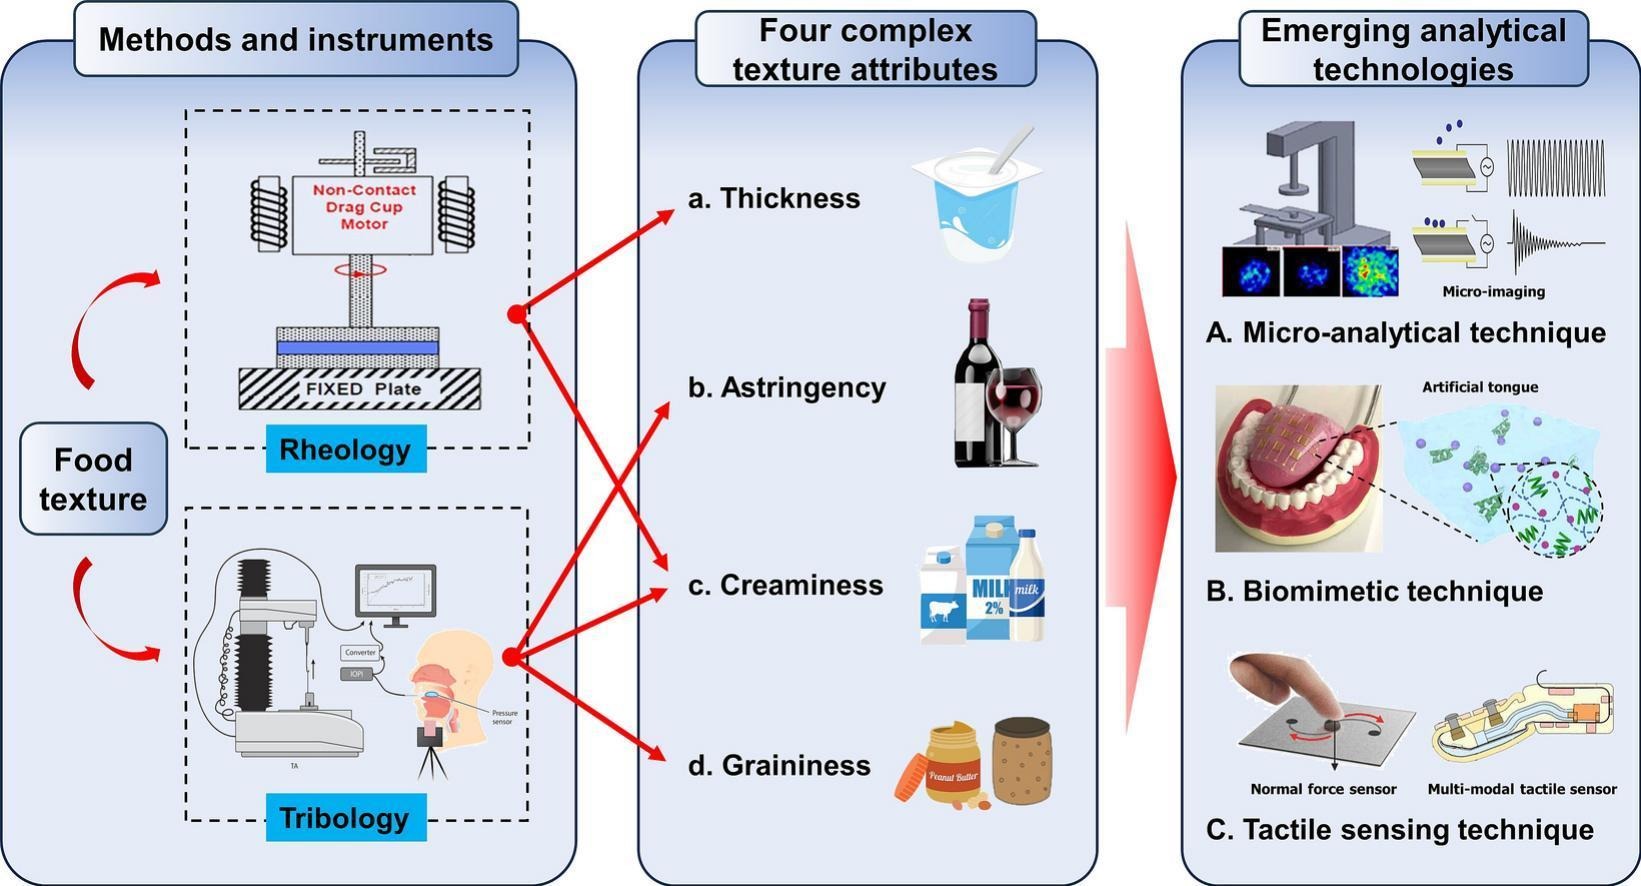
Methods and Instruments for the Evaluation of Food Texture: Advances and Perspectives

Liwen Huang, Jie Fan, Chaoyue Han, Chengjin Du, Zhenbo Wei, Dongdong Du

Food Research International, 2025.

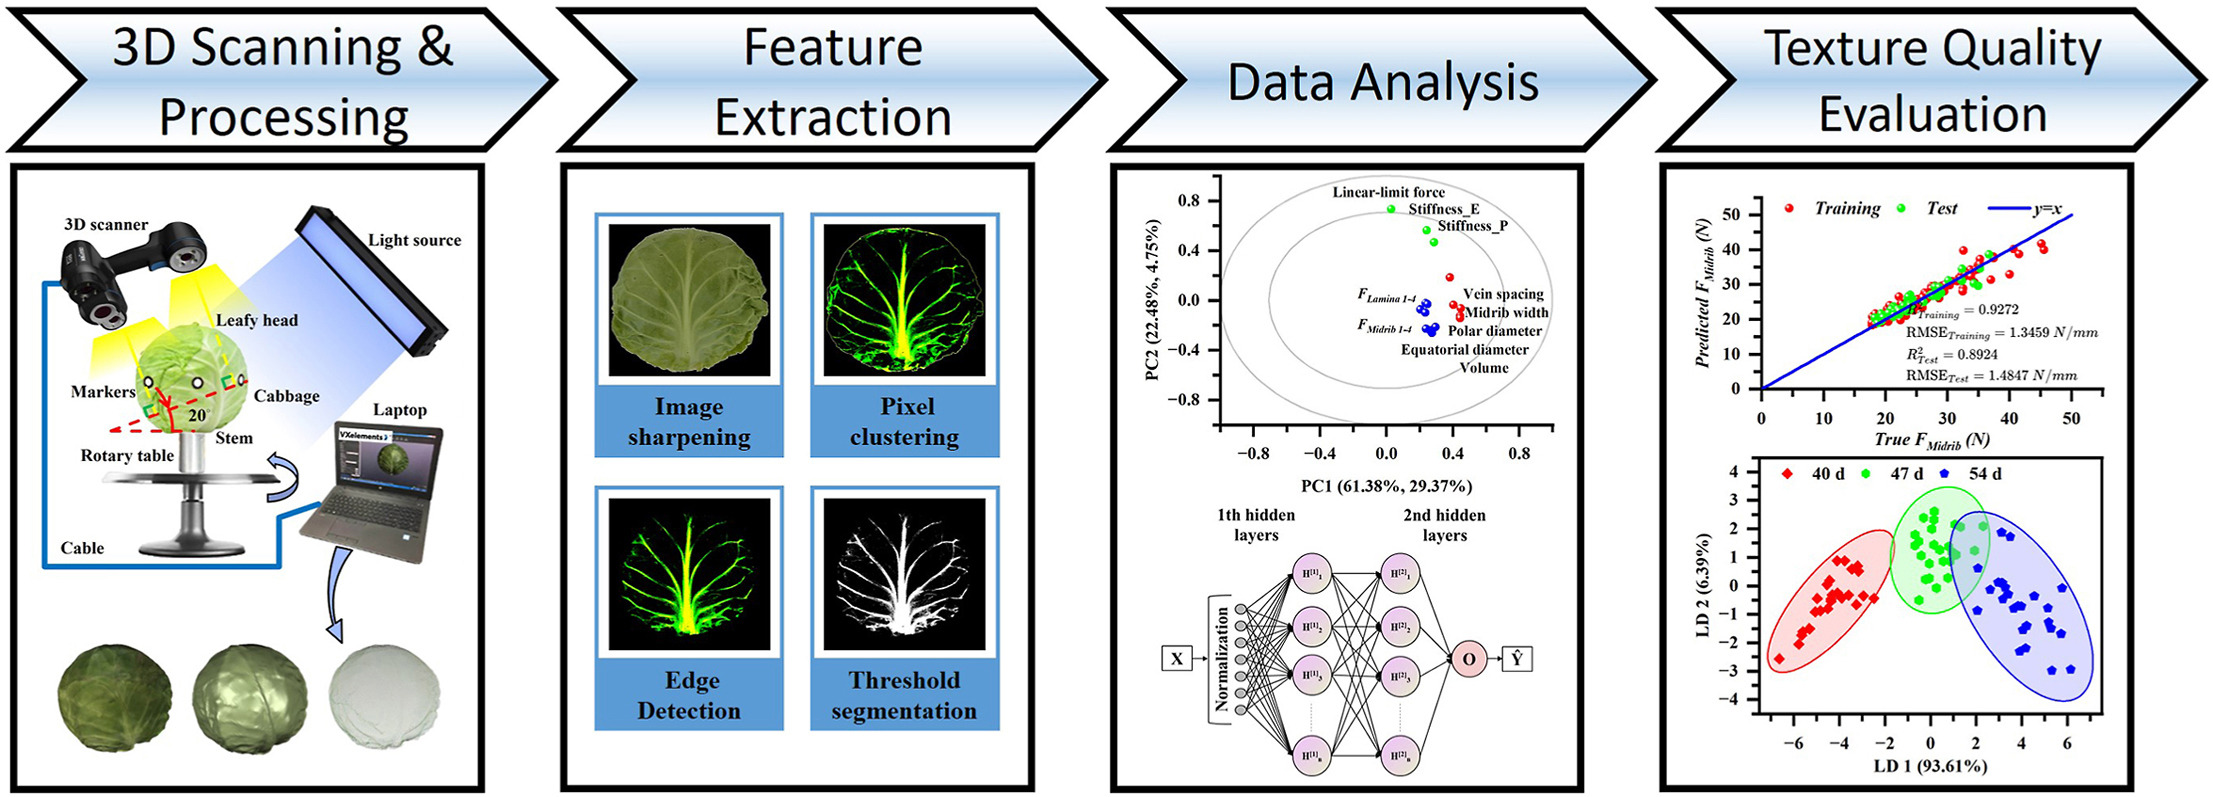
Nondestructive Evaluation of Harvested Cabbage Texture Quality Using 3D Scanning Technology

Dongdong Du, Yongkai Ye, Dongfang Li, Jie Fan, Rob B.N. Scharff, Jun Wang, Fake Shan

Journal of Food Engineering, 2024.

An Image-Based Method for the Morphological Analysis of Tendrils with 2D Piece-Wise Clothoid Approximation Model

Jie Fan, Francesco Visentin, Emanuela Del Dottore, Barbara Mazzolai

Biomimetic and Biohybrid Systems, Living Machines, 2021.

Image-Based Approach to Reconstruct Curling in Continuum Structures

Jie Fan, Emanuela Del Dottore, Francesco Visentin, Barbara Mazzolai

IEEE International Conference on Soft Robotics (RoboSoft), 2020.

Dissertations and Technical Papers

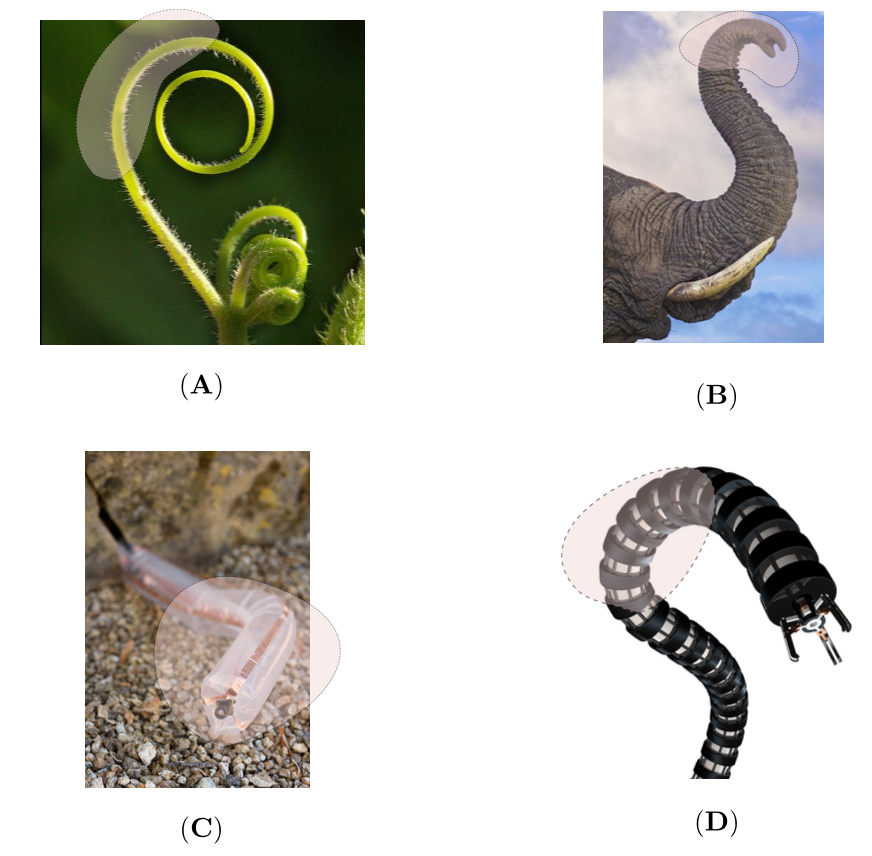
Morphological Characterization and Analysis of Thin, Continuum Structures Based on Non-constant Curvature Clothoid Spiral: Taking Inspiration from Climbing Organs-Tendrils

Jie Fan

Ph.D. Dissertation, Scuola Superiore Sant'Anna & Italian Institute of Technology, 2023.

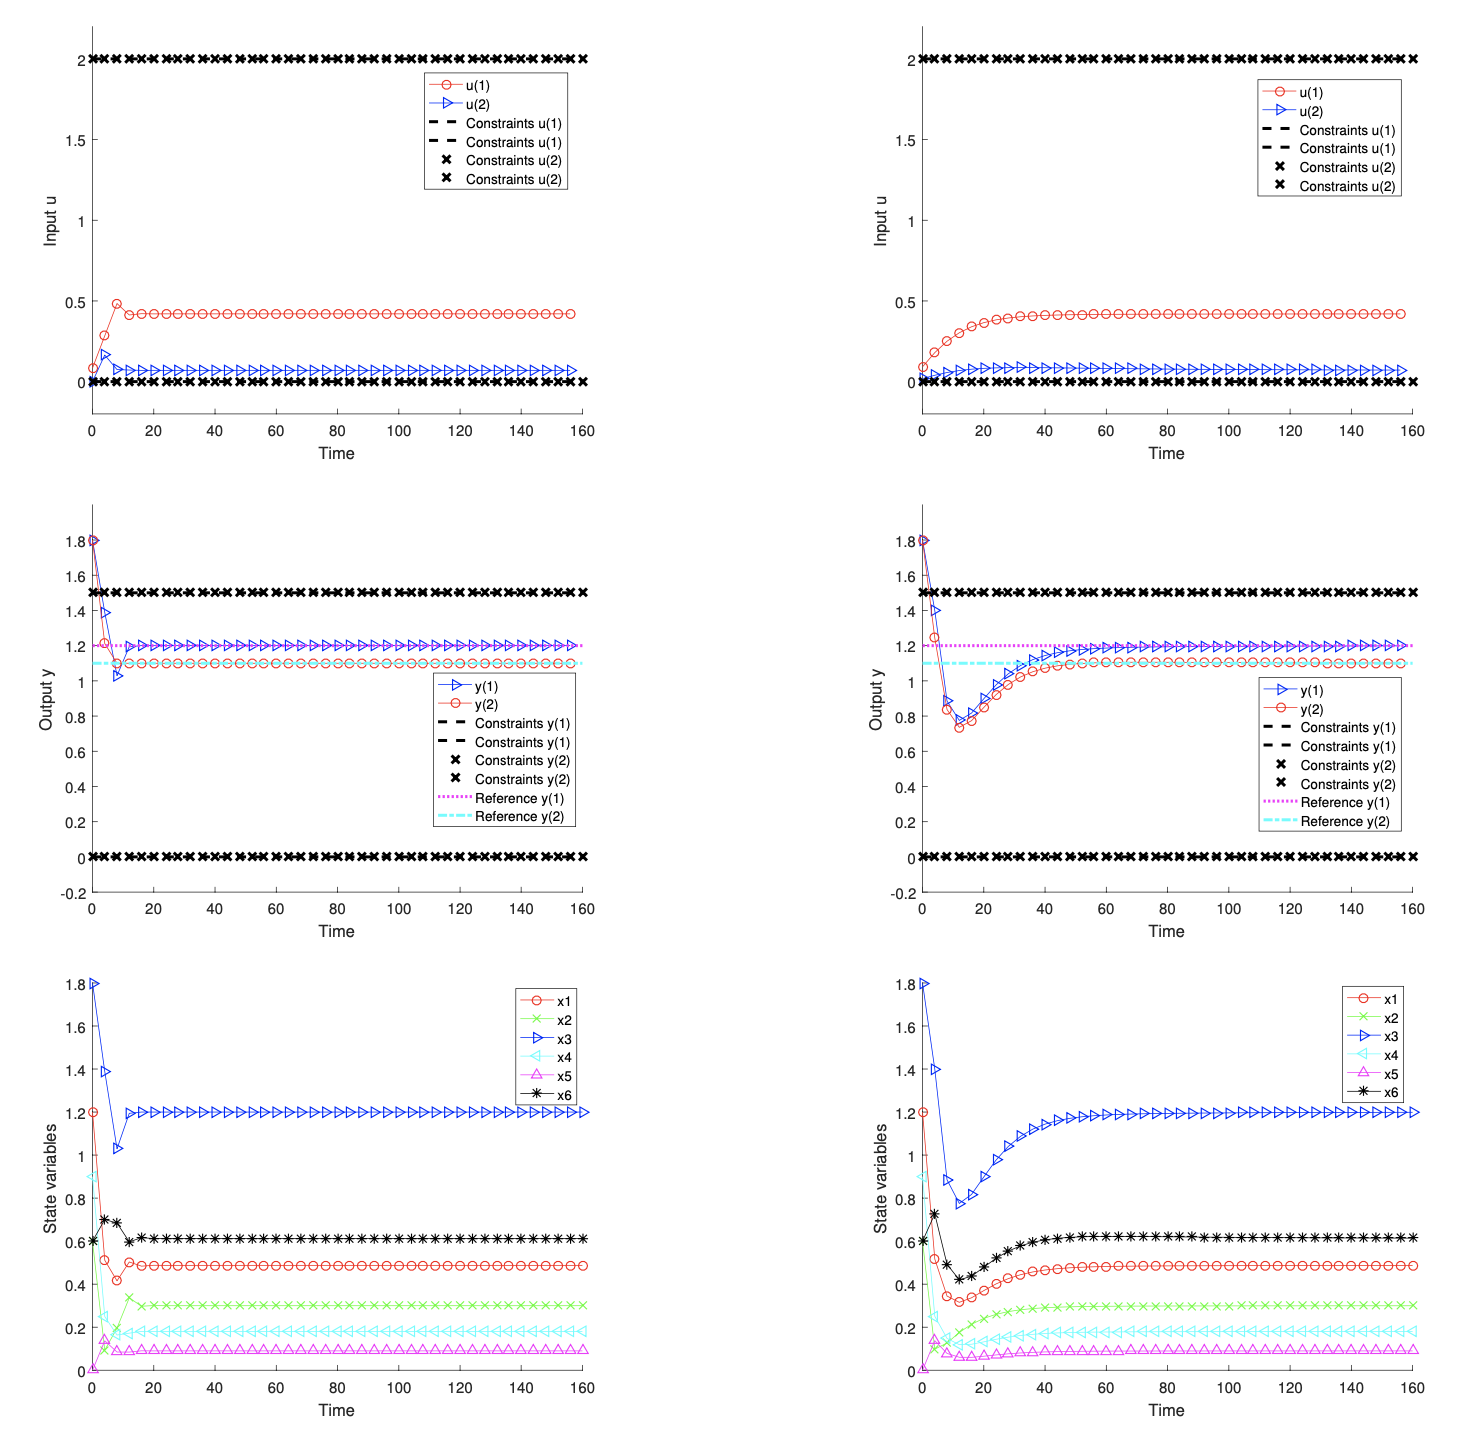
Receding Horizon Optimal Control (RHOC)

Jie Fan

M.Sc. Thesis, INSA de Lyon, 2016.

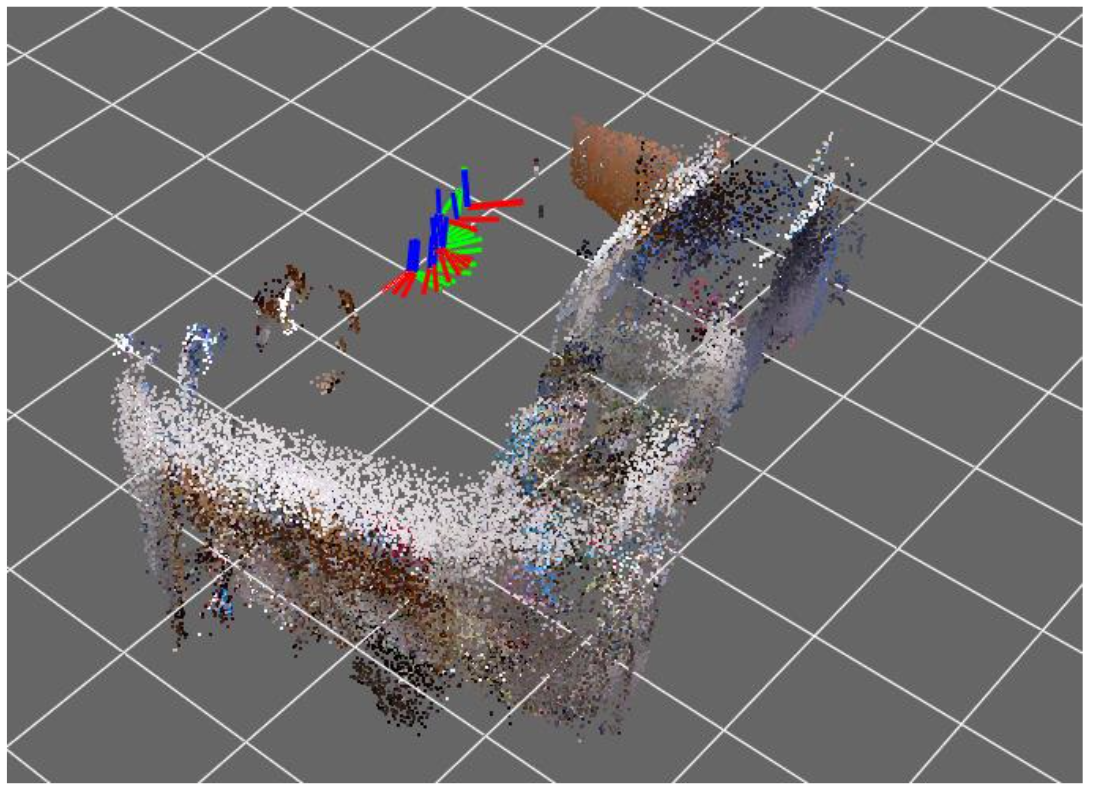
3D Scene Reconstruction and Localization of Indoor Environment and Pose Estimation of the Camera

Jie Fan

B.S. Thesis, Northwestern Polytechnical University, 2013.

Outstanding Dissertation Award.

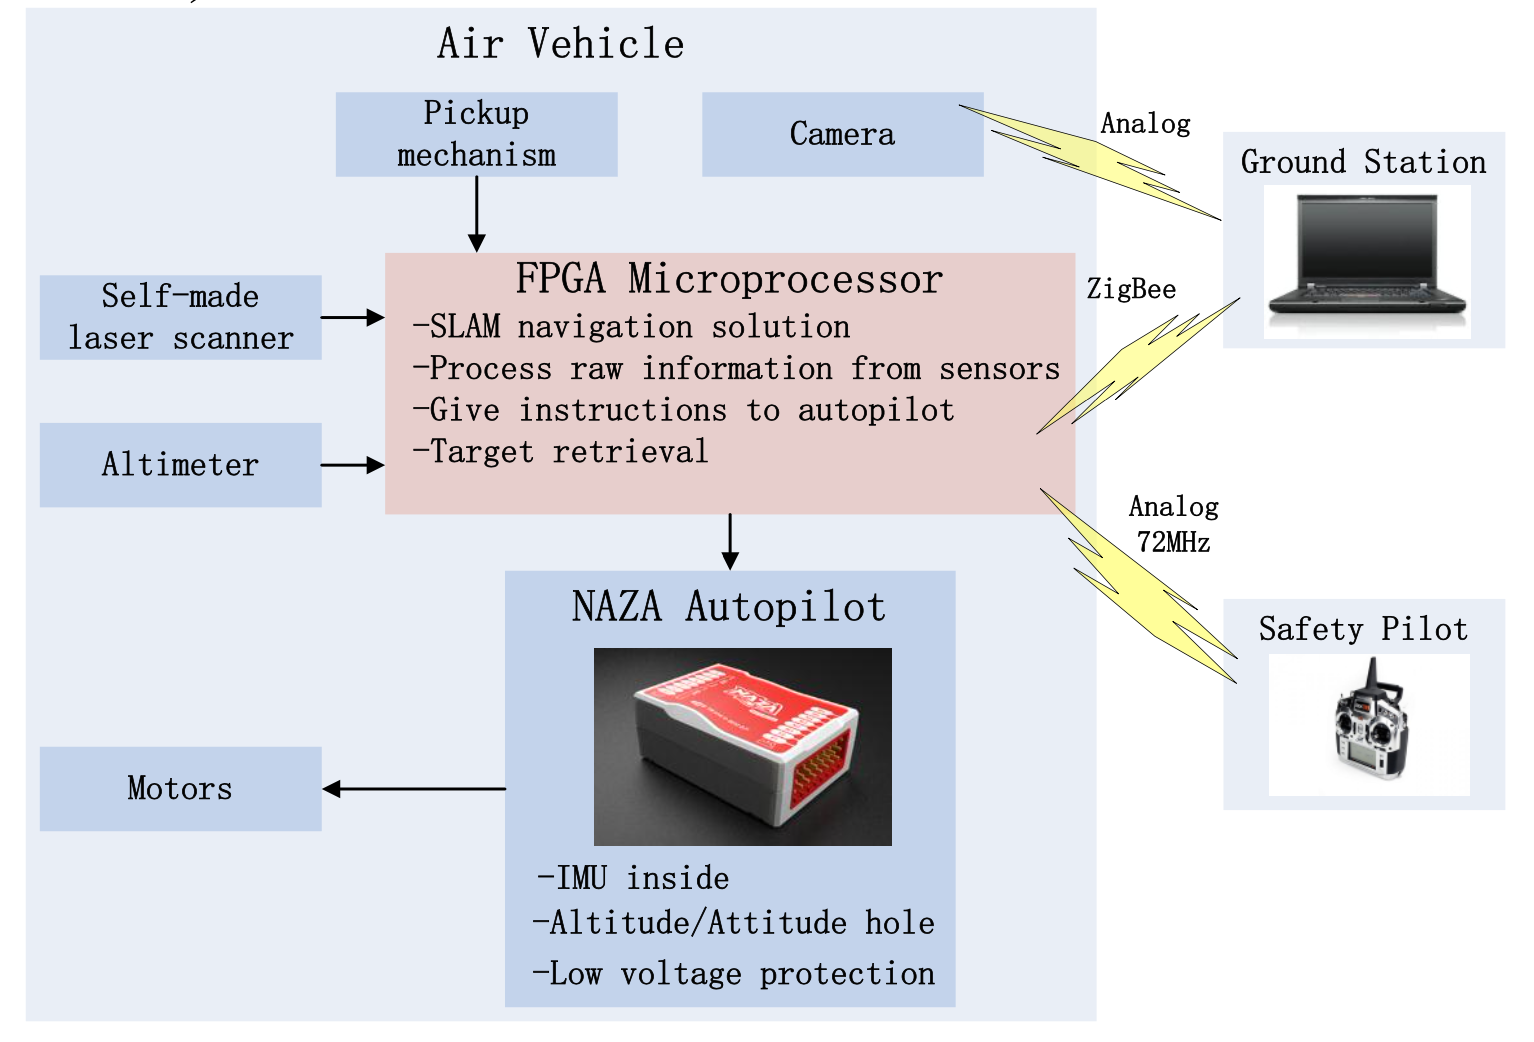
Northwestern Polytechnical University Team Entry for the AUVSI International Aerial Robotics Competition

Fei Liu, Yinan Sang, Jie He, Jie Chen, Jie Fan, Ruichao Li, Haoyu Li

International Aerial Robotics Competition (IARC) Symposium, Aug. 2012.

Innovative Design Award & Excellent Team Culture Award.

Competitions & Awards

Full Ph.D. Scholarship

Italian Institute of Technology & Scuola Superiore Sant'Anna | Pisa, Italy | 2018 - 2023

DJI RoboMasters Mobile Manipulation Challenge (RoboMasters)

Team Coordinator | Shenzhen, China | 2014

Implemented fast onboard object tracking and recognition algorithms and contributed to autonomous mobile robot design using visual SLAM.

Outstanding Dissertation Award

Northwestern Polytechnical University | Xi'an, China | 2013

Awarded for undergraduate thesis work, ranked in the top 3%.

International Aerial Robotics Competition (IARC)

Team Assistant | Beijing, China | 2012

Worked on environment mapping, quadrotor control, point-cloud-based wall and window detection, and team paper writing; received Innovative Design & Excellent Team Culture awards.

Robotics and Modeling Competitions

Northwestern Polytechnical University | Xi'an, China | 2010 - 2011

Received awards in the Freescale Cup smart car competition, FIRA China-Cup humanoid robot penalty kick competition, and NWPU mathematical modeling contest.